Yifei Yao
Exploratory, Communicative, and Deployable: Vision-Driven Embodied Agents for Open-World Mobile Manipulation
Vision-driven mobile manipulation through active exploration, visual grounding, and interactive intent disambiguation, with a shared interface for simulation and real robots.
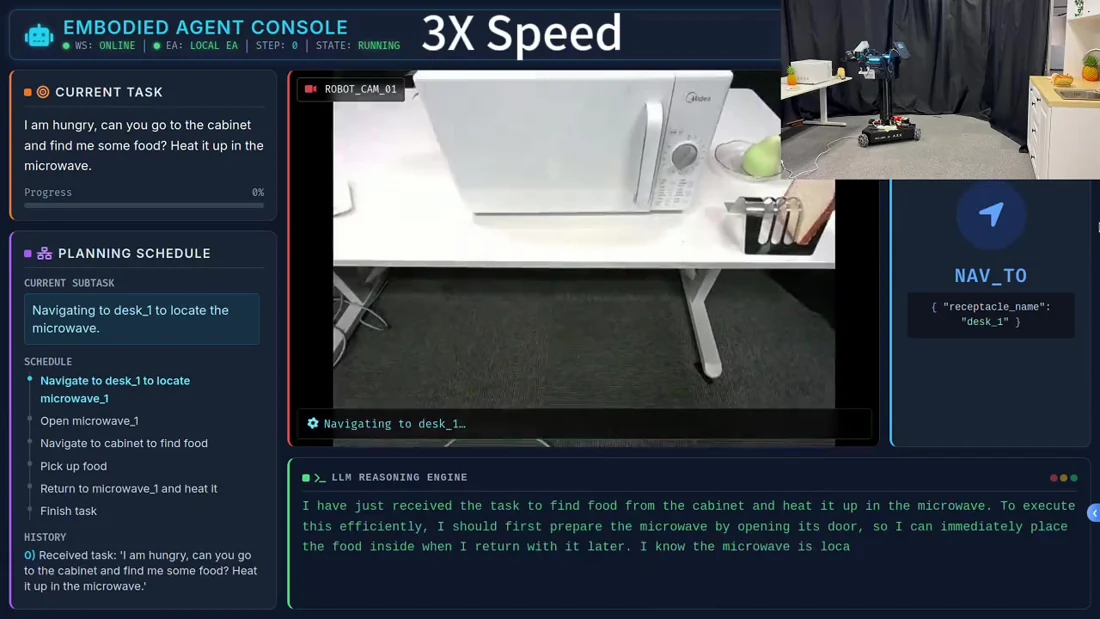
REAL combines data collection, supervised fine-tuning, and online reinforcement learning for open-world embodied agents. REAL-Bench covers 241 tasks involving exploration, visual distractors, articulated manipulation, and interactive disambiguation.
The paper reports a 78.3% end-to-end success rate over 60 real-robot episodes on a physical dual-arm mobile robot. See the paper for the evaluation protocol and limitations.
Reference
BibTeX
@inproceedings{yao2026real,
  title = {Exploratory, Communicative, and Deployable: Vision-Driven Embodied Agents for Open-World Mobile Manipulation},
  author = {Mi, Boyu and Ma, Mengchen and Yao, Yifei and Gao, Xing and Chen, Junting and Li, Yangzi and Zhu, Zihou and Li, Guohao and Yin, Zhenfei and Wang, Tai and Mu, Yao and Pang, Jiangmiao and Wang, Hanqing},
  year = {2026},
  url = {https://arxiv.org/abs/2607.13653},
  booktitle = {European Conference on Computer Vision (ECCV 2026)},
  eprint = {2607.13653},
  archivePrefix = {arXiv},
  primaryClass = {cs.CV}
}Metadata checked October 27, 2026. Original source ↗