Yifei Yao
AnyBipe: An Automated End-to-End Framework for Training and Deploying Bipedal Robots Powered by Large Language Models
Language-guided reward design, reinforcement learning, and sim-to-real evaluation in one end-to-end pipeline for bipedal robots.
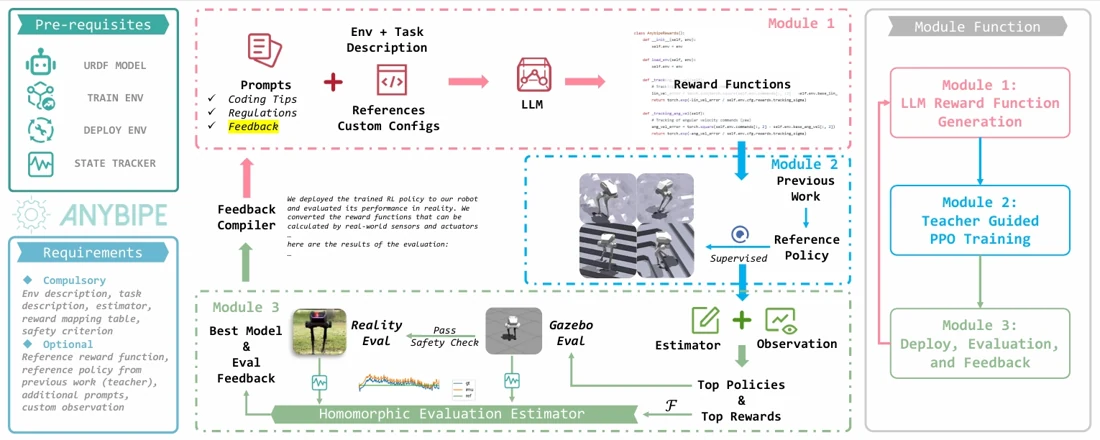
AnyBipe links an LLM-guided reward-design module, reinforcement learning, and a sim-to-real homomorphic evaluation module. The public implementation includes training and deployment tools for bipedal locomotion.
The final IROS 2025 title is shown above. The linked arXiv version uses the earlier title “AnyBipe: An End-to-End Framework for Training and Deploying Bipedal Robots Guided by Large Language Models” and was first submitted in September 2024. These versions are listed once here.
Published: IROS 2025, pp. 14790–14797. DOI: 10.1109/IROS60139.2025.11246492.
Reference
BibTeX
@inproceedings{Yao_2025,
  title = {AnyBipe: An Automated End-to-End Framework for Training and Deploying Bipedal Robots Powered by Large Language Models},
  url = {http://dx.doi.org/10.1109/IROS60139.2025.11246492},
  DOI = {10.1109/iros60139.2025.11246492},
  booktitle = {2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  publisher = {IEEE},
  author = {Yao, Yifei and He, Wentao and Gu, Chenyu and Du, Jiaheng and Tan, Fuwei and Zhu, Zhen and Lu, Jun-Guo},
  year = {2025},
  month = Oct,
  pages = {14790--14797}
}Metadata checked October 27, 2026. Original source