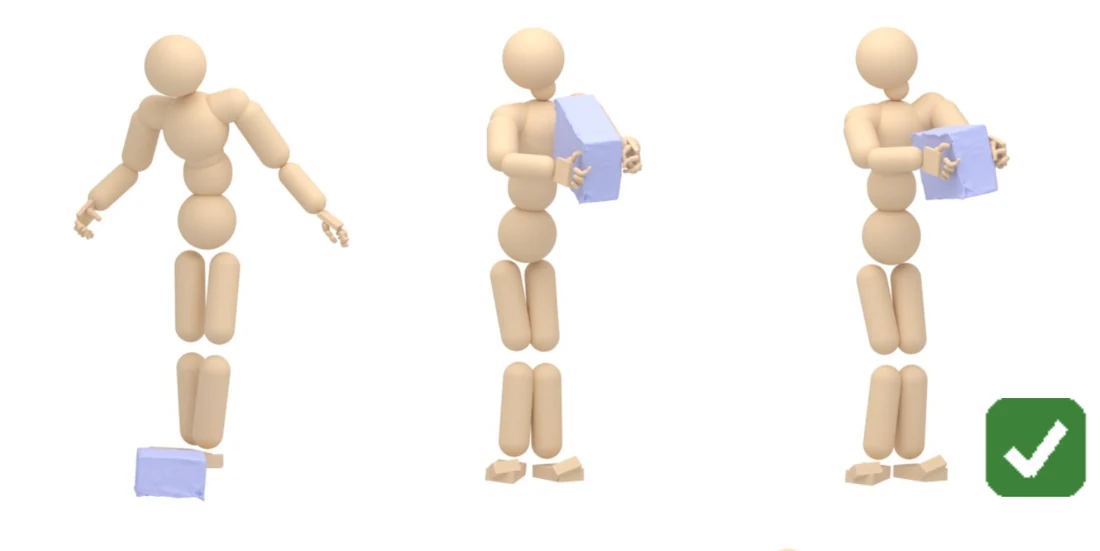
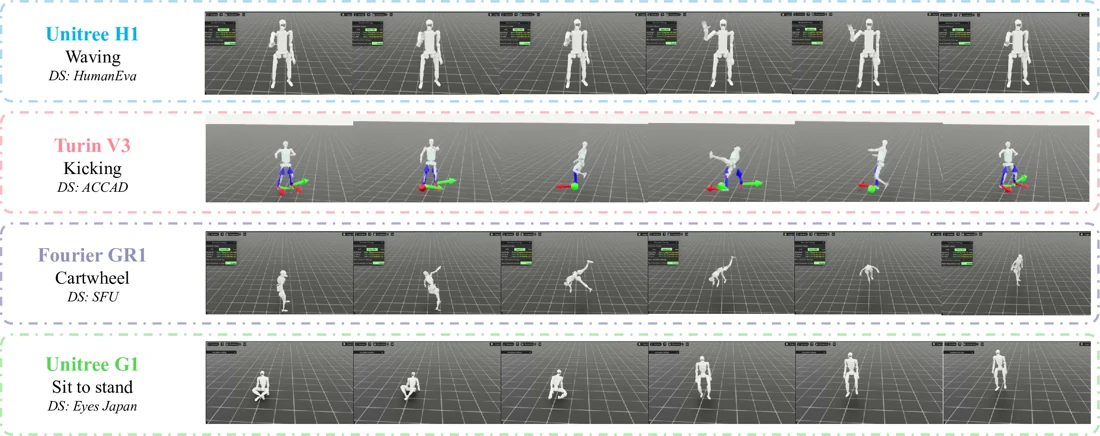
Make generated motion executable. InfCoiL lets a flow-matching planner and a physics-based controller improve each other through shared rollout feedback, alternating their RL updates when progress plateaus.
Qualitative S=2 planner / C45k controller rollout from the project page. The goal ring turns green on stable arrival. Five-frame display smoothing and a final-pose hold are part of the source video; this clip is separate from the paper benchmark. Source
Replanning through tripod transport
A second object and transport task from the same qualitative release, with the same display smoothing and final-pose hold. Source
Boyu Mi*, Mengchen Ma*, Yifei Yao*, Xing Gao, Junting Chen, Yangzi Li, Zihou Zhu, Guohao Li, Zhenfei Yin, Tai Wang, Yao Mu, Jiangmiao Pang, Hanqing Wang
* Equal contribution (co-first authors).
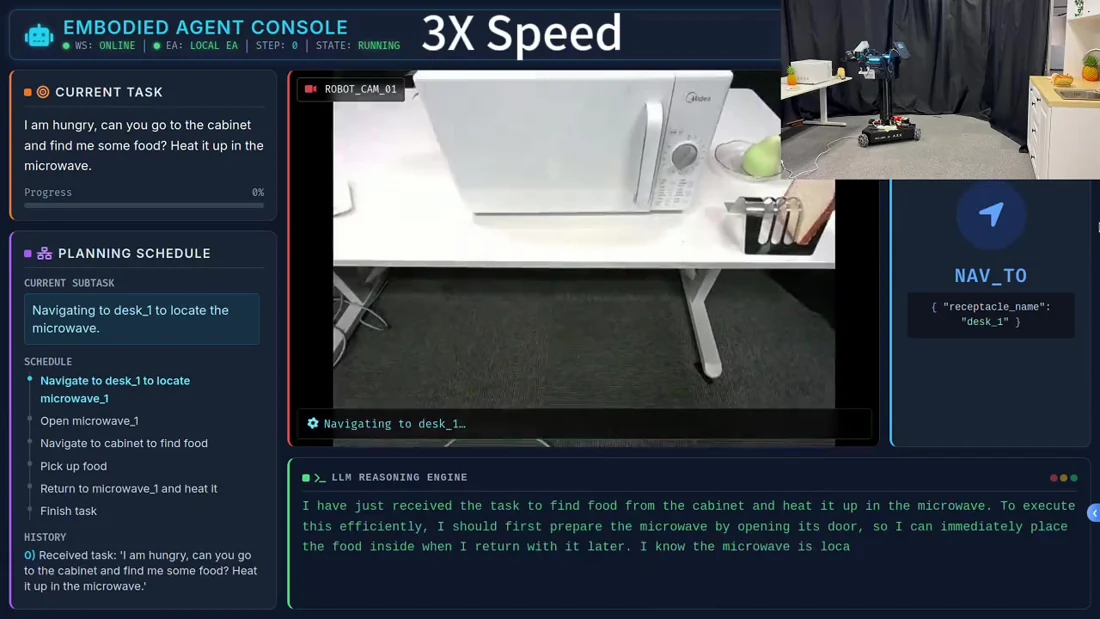
Vision-driven mobile manipulation through active exploration, visual grounding, and interactive intent disambiguation, with a shared interface for simulation and real robots.